Autonomous path planning
for VEX teams.
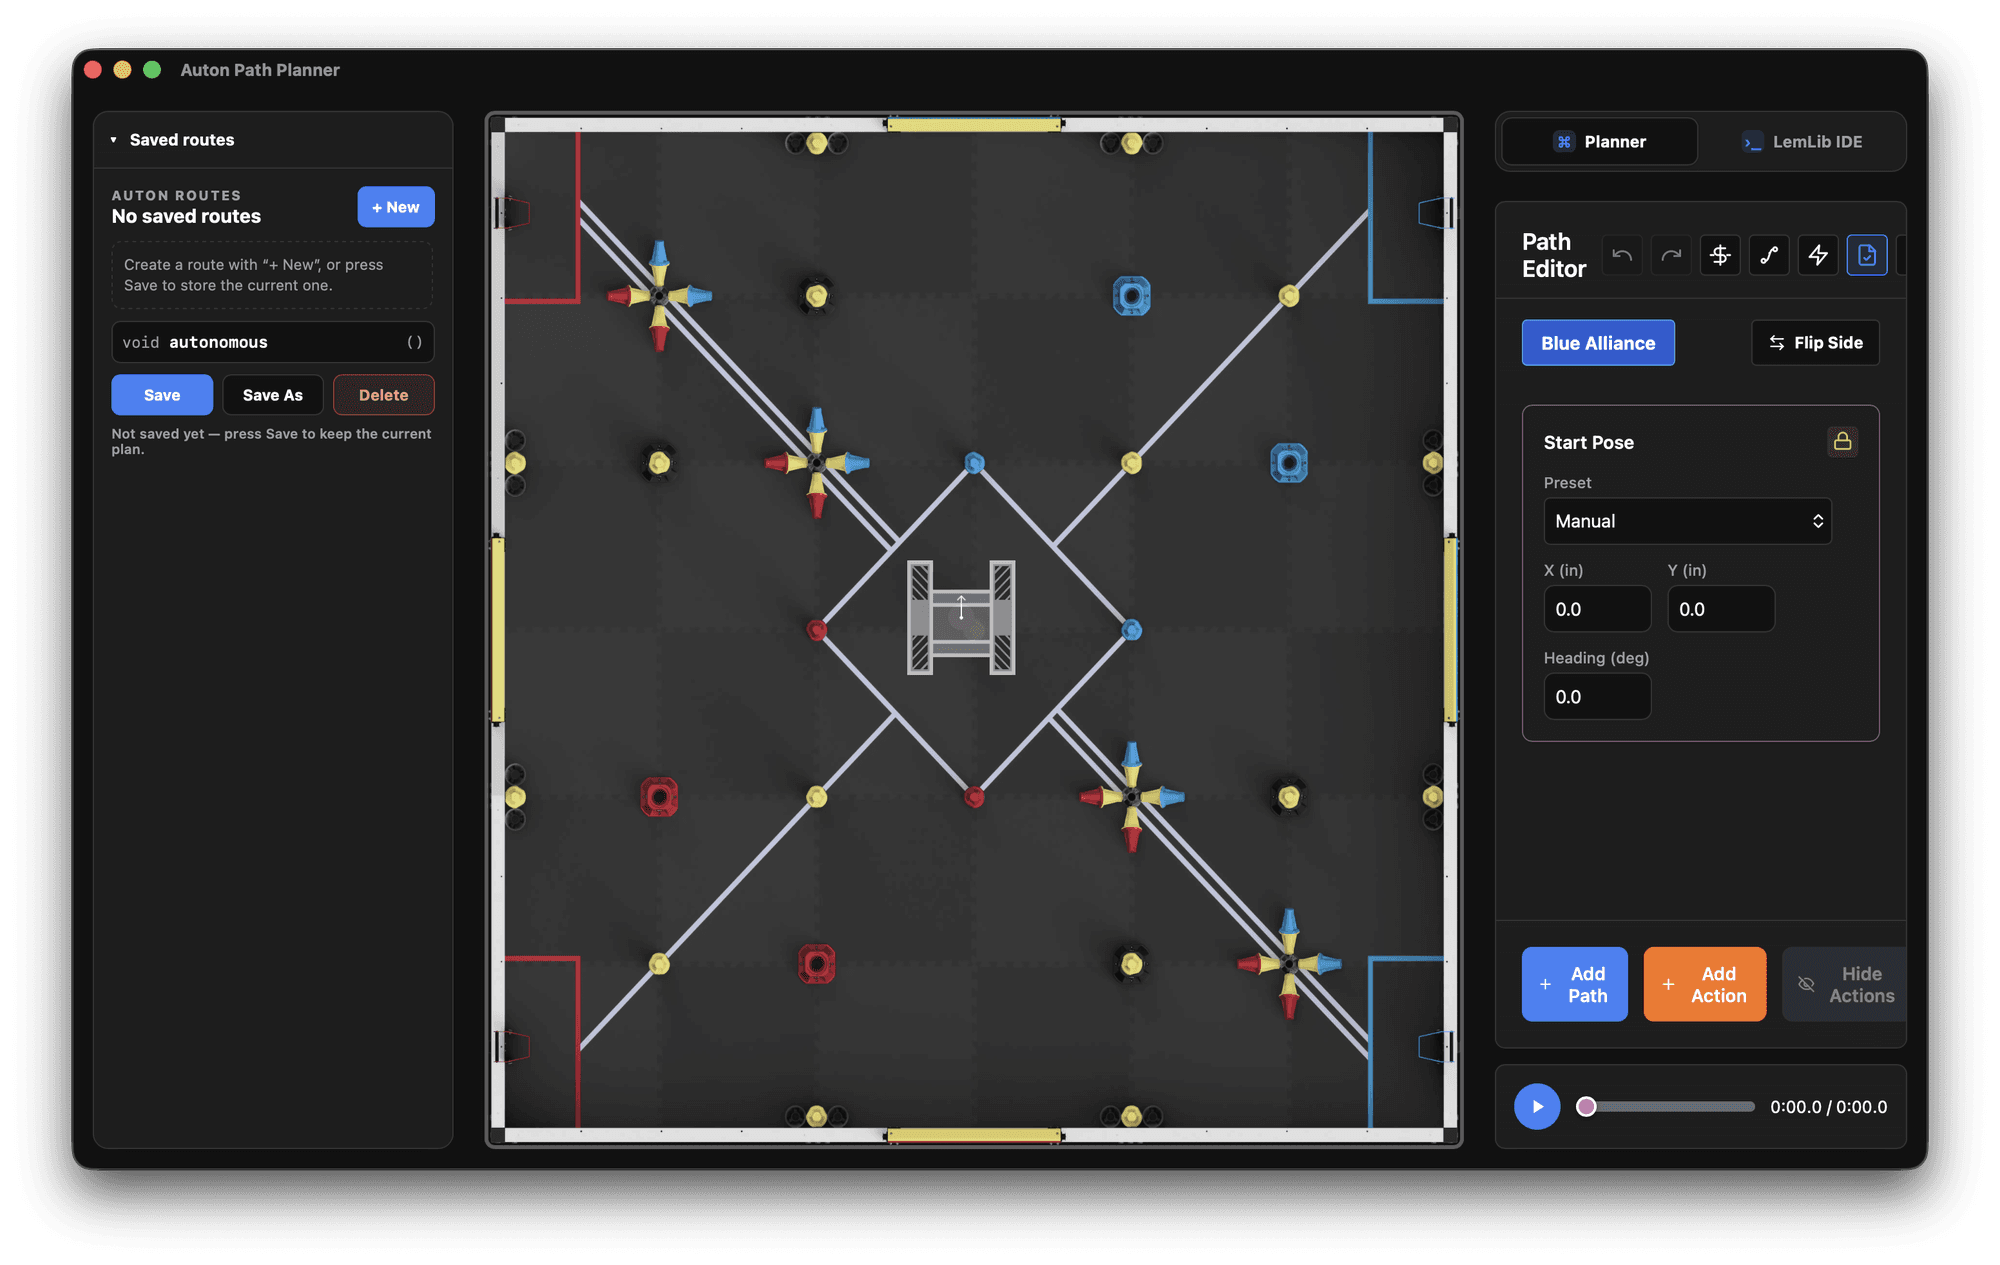
Visual auton editor for VRC 82855T. Drag waypoints on a field, tune with playback, and export straight to LemLib C++ for PROS.
Also for Windows · macOS · Linux · all releases
Latest release · v0.12.7
Public build available — vex-tools-v0.12.7 with Tauri .dmg/.msi/.AppImage assets. Downloads resolve via Worker when GITHUB_TOKEN is set for private repos, otherwise via github.com/RandomPerson5571/VexRobotics/releases/latest.
Workflow
From whiteboard sketch to C++ in minutes
Sketch
Drag waypoints on a real field image. Add paths, turns, and intake actions in the sequence.
Tune
Scrub playback, adjust headings and speed, then mirror the whole route for the other alliance.
Export
Generate LemLib C++ with constants and poses — paste straight into your PROS project.
Visual path editor
Drag waypoints on a field canvas with bezier control points, per-point headings, and undo history — tuned for VEX fields.
LemLib export
Generates idiomatic LemLib C++ for your PROS project — paths, constants, and poses.
chassis.setPose(0, 0, 0);
chassis.moveToPose(24, 24,
90, 2000);
chassis.turnToHeading(118, 1000);
One route, both alliances
Flip the whole auton across the field axis — headings, turns, and control points re-mirror automatically.
Playback before the field
Simulate the route with your robot's constants. Catch bad headings at practice, not at inspection.
Offline-first
Tauri + SQLite. No Wi-Fi at comps. Auto-updater keeps the team current between events.
System requirements
- macOS 12+ (Apple Silicon & Intel) · Windows 10+ · Ubuntu 22.04+
- ~150 MB · no admin rights for portable builds
- PROS only for flashing — planning is standalone
How releases ship
- 01 — npm --prefix apps/vex-tools run build
- 02 — push vex-tools-v0.12.7 → CI uploads .dmg · .msi
- 03 — landing fetches release metadata via the vex-tools-updater Worker
Revalidated every 5 min · PAT lives in the Worker, not this host
VEX Tools v0.12.7 — public build live
v0.12.7 · direct downloads via Worker